
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
Universal Robots
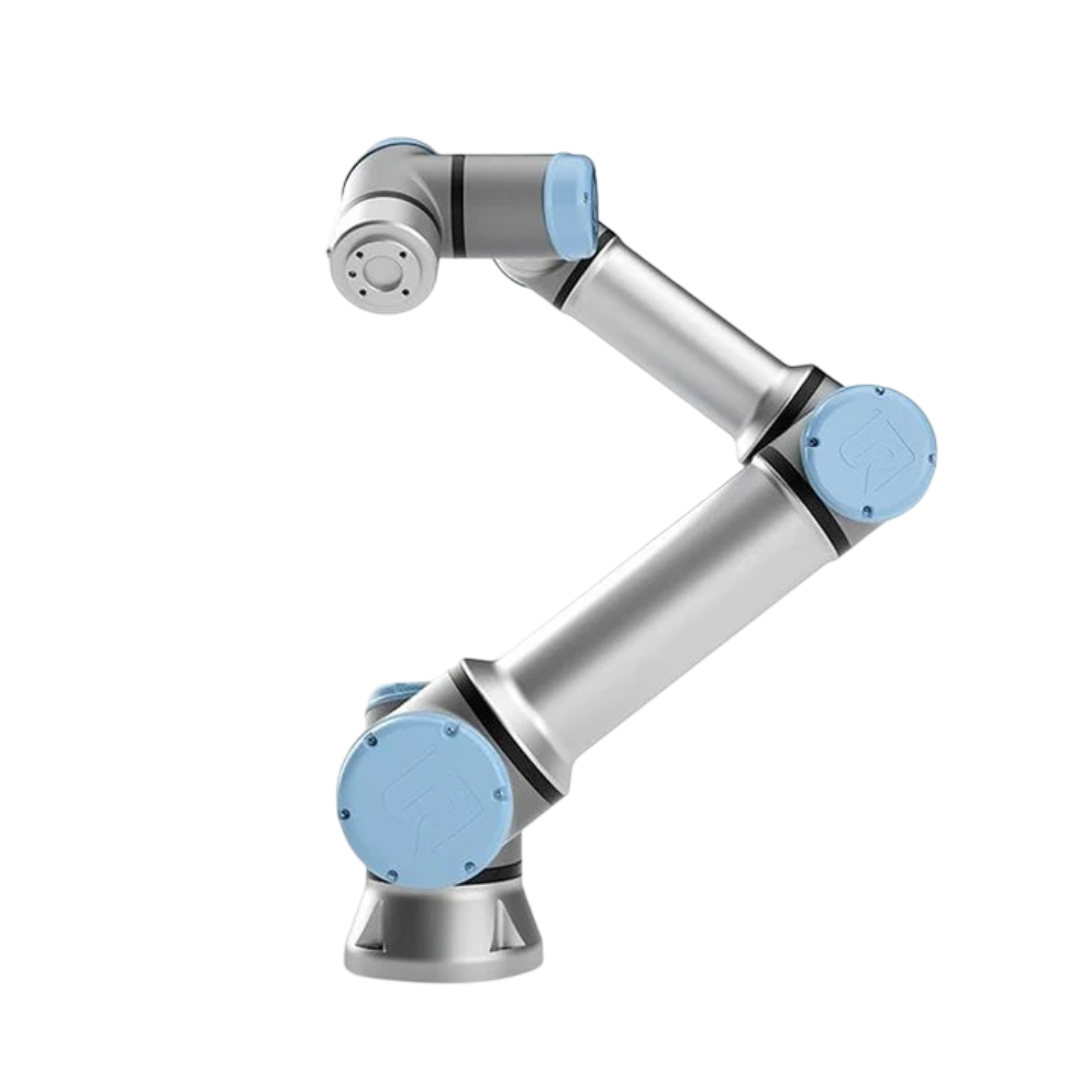
The UR16e is a six-axis collaborative robot with 16 kg payload capacity, 900 mm reach, and 0.05 mm repeatability. IP54-rated and weighing 33.1 kg, it handles machine tending, material handling, assembly, grinding, and inspection tasks with Polyscope 5 software control and URCaps extensibility.
The Universal Robots UR16e collaborative robot is a six-axis industrial cobot designed for machine tending, material handling, and heavy-duty assembly operations in manufacturing environments.
Manufactured by Universal Robots as part of the e-Series family, the UR16e is optimized for industrial automation tasks requiring precision and reliability where high payload and compact footprint are critical. Robust construction with an IP54 enclosure suits a range of production environments. The UR16e collaborative robot is positioned as a higher payload alternative to the UR10e, and a more compact option compared to the UR20.
Programming and configuring the UR16e robot is handled through Polyscope 5 software on a 12-inch touchscreen teach pendant, streamlining deployment and operation. The system supports both digital and analog I/O, as well as 12 V and 24 V tool power. URCaps extensions enable third-party peripheral and accessory integration. Learn more about Polyscope 5 and URCaps software extensions for additional customization.
The Universal Robots UR16e is recommended where handling multiple workpieces, heavy components, or large tooling within limited spaces is required. Sub-millimeter repeatability ensures suitability for precision processes on high-throughput manufacturing lines.
The UR16e bridges the gap between manual labor and rigid fixed-line automation. It lifts 16 kg loads across a 900 mm reach in confined spaces where larger gantries or conventional robotic arms cannot fit, yet handles precision and throughput better than hand assembly or machine tending by an operator.