
Not sure it fits your cell? Book 20 minutes with an engineer who has specified this part before.
Book a callOrdered the wrong size or interface? Here is exactly how sending it back works.
igus®
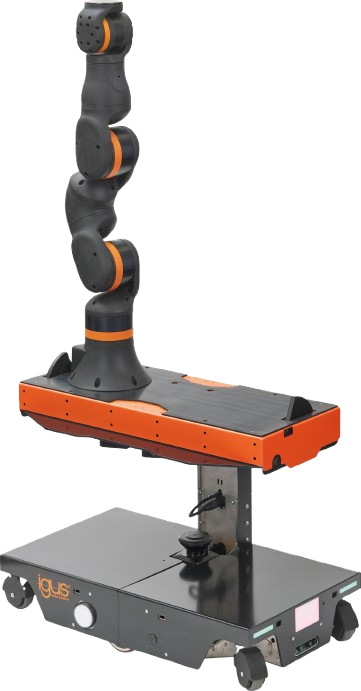
igus ReBeLMove is a 35 kg autonomous mobile robot that transports payloads up to 50 kg at speeds to 1.5 m/s. It holds Performance Level D safety certification with integrated laser scanner, dual-channel emergency stop, and motor brakes active in all modes, including manual push and docking. It navigates autonomously via WLAN, detects obstacles, and stops safely when safety fields are breached.
The igus ReBeLMove AMR Robot is an autonomous mobile robot purpose-built for material transport in industrial environments demanding continuous safety compliance.
Manufacturer igus equips the ReBeLMove AMR Robot with integrated safety hardware including a laser scanner, dual-channel emergency stop, motor encoders, and braking systems on both drive motors. These features deliver uninterrupted collision avoidance and protective stopping, maintaining compliance across all operating modes, such as manual push and station docking.
The ReBeLMove autonomously selects optimal paths in free space, rerouting as needed to avoid detected obstacles. When objects breach predefined safety zones, the braking system initiates a controlled stop for hazard response.
The robot integrates with fleet management systems, supporting both live and offline operation modes.
Compared to other mobile robots or automated guided robots for material handling, the ReBeLMove offers continuous safety functions, robust collision avoidance, and dual-mode connectivity. Its integrated hardware safety suite, combined with a 50 kg payload and Performance Level D certification, differentiates it in environments where reliable protection and fleet communication are essential.
The igus ReBeLMove is a safety-certified autonomous mobile robot designed for continuous material transport without fixed routes or external infrastructure. It differs from manual carts by eliminating human pushing and from conventional AGVs by enabling free-space navigation with independent obstacle avoidance rather than following pre-laid tracks or magnetic tape.